Episode Details
Back to Episodes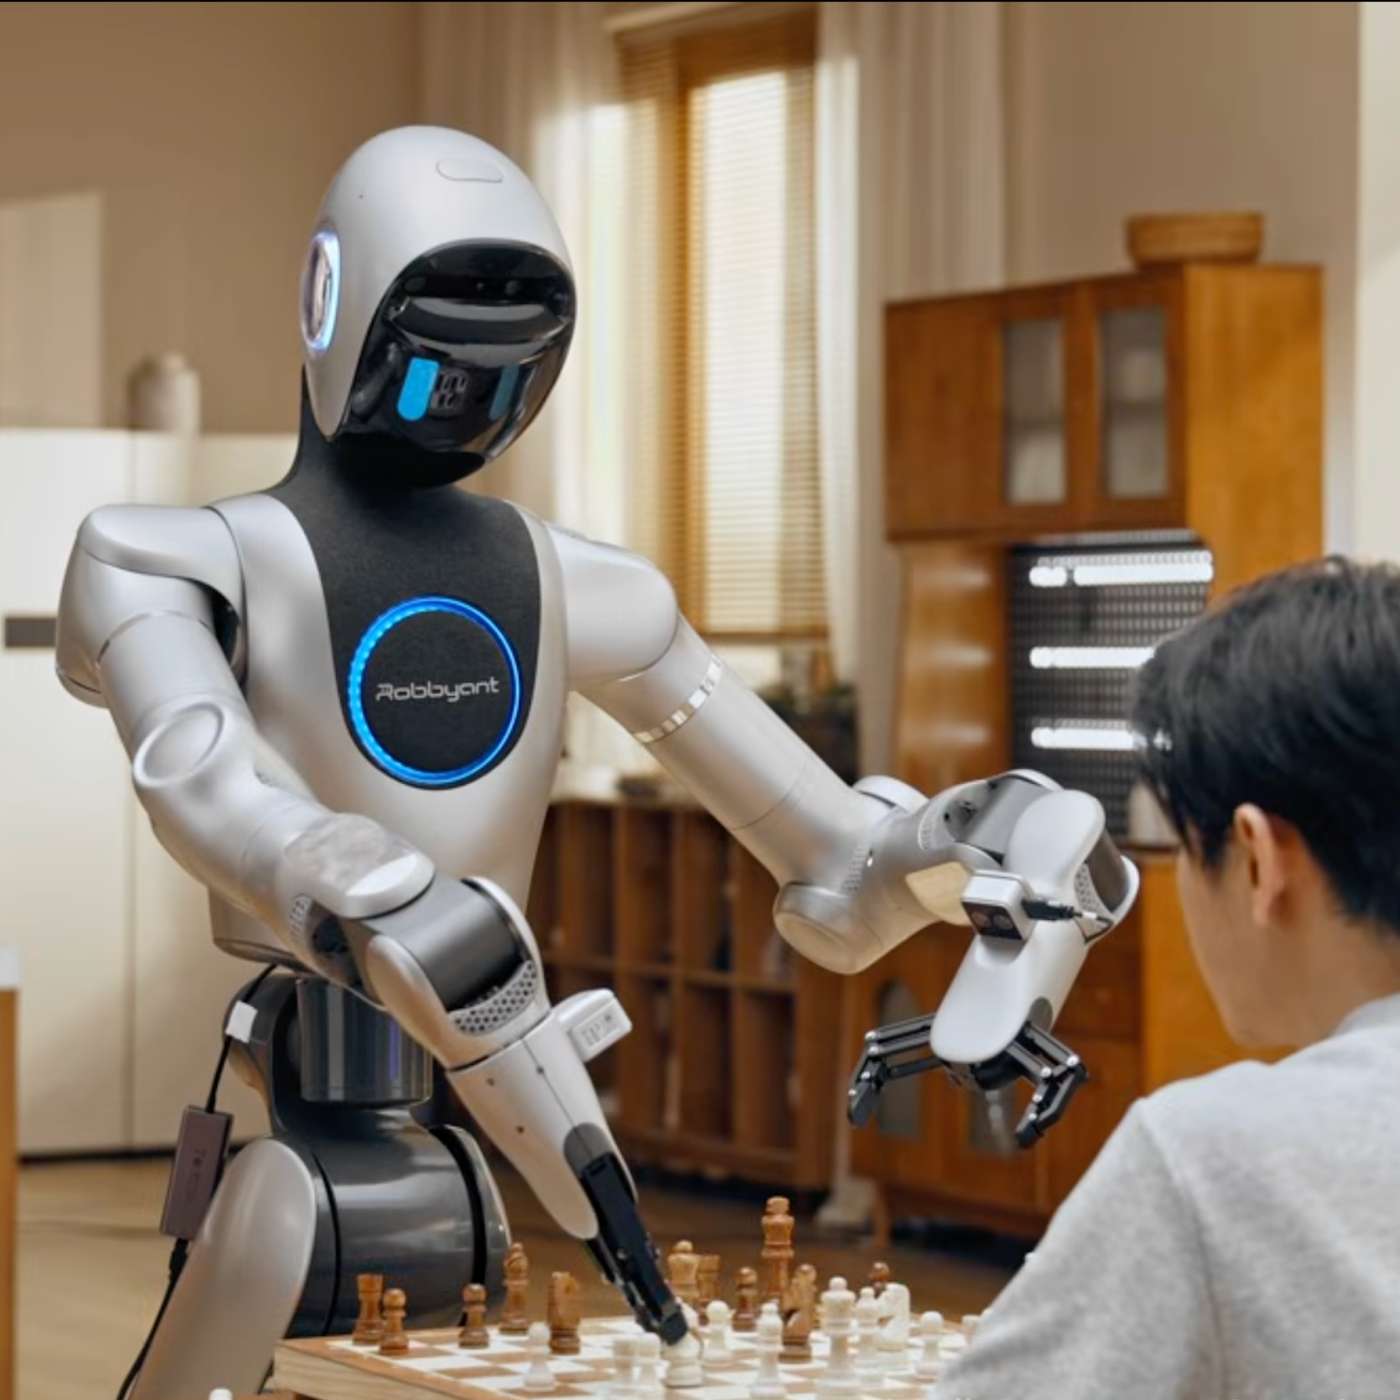
Why Robots Need Intelligence Built for the Physical World
Description
This story was originally published on HackerNoon at: https://hackernoon.com/why-robots-need-intelligence-built-for-the-physical-world.
Discover how Robbyant’s LingBot 2.0 connects perception, world modeling, and physical action to build embodied intelligence across different robot bodies.
Check more stories related to undefined at: https://hackernoon.com/c/undefined.
You can also check exclusive content about #physical-ai-systems, #cross-embodiment-ai, #multi-robot-ai-architecture, #embodied-ai, #robbyant-lingbot-2.0, #world-models-in-robotics, #robot-perception-and-action, #good-company, and more.
This story was written by: @jonstojanjournalist. Learn more about this writer by checking @jonstojanjournalist's about page,
and for more stories, please visit hackernoon.com.
Robbyant’s LingBot 2.0 takes a full-stack approach to embodied AI, designing intelligence around the demands of physical environments rather than adapting systems built for language or entertainment. Its six models cover perception, spatial understanding, world modeling, prediction, and execution. By connecting these capabilities and training across 20 robot configurations from 17 brands, the architecture aims to support intelligent behavior across different robot bodies and real-world settings.